Mechanical
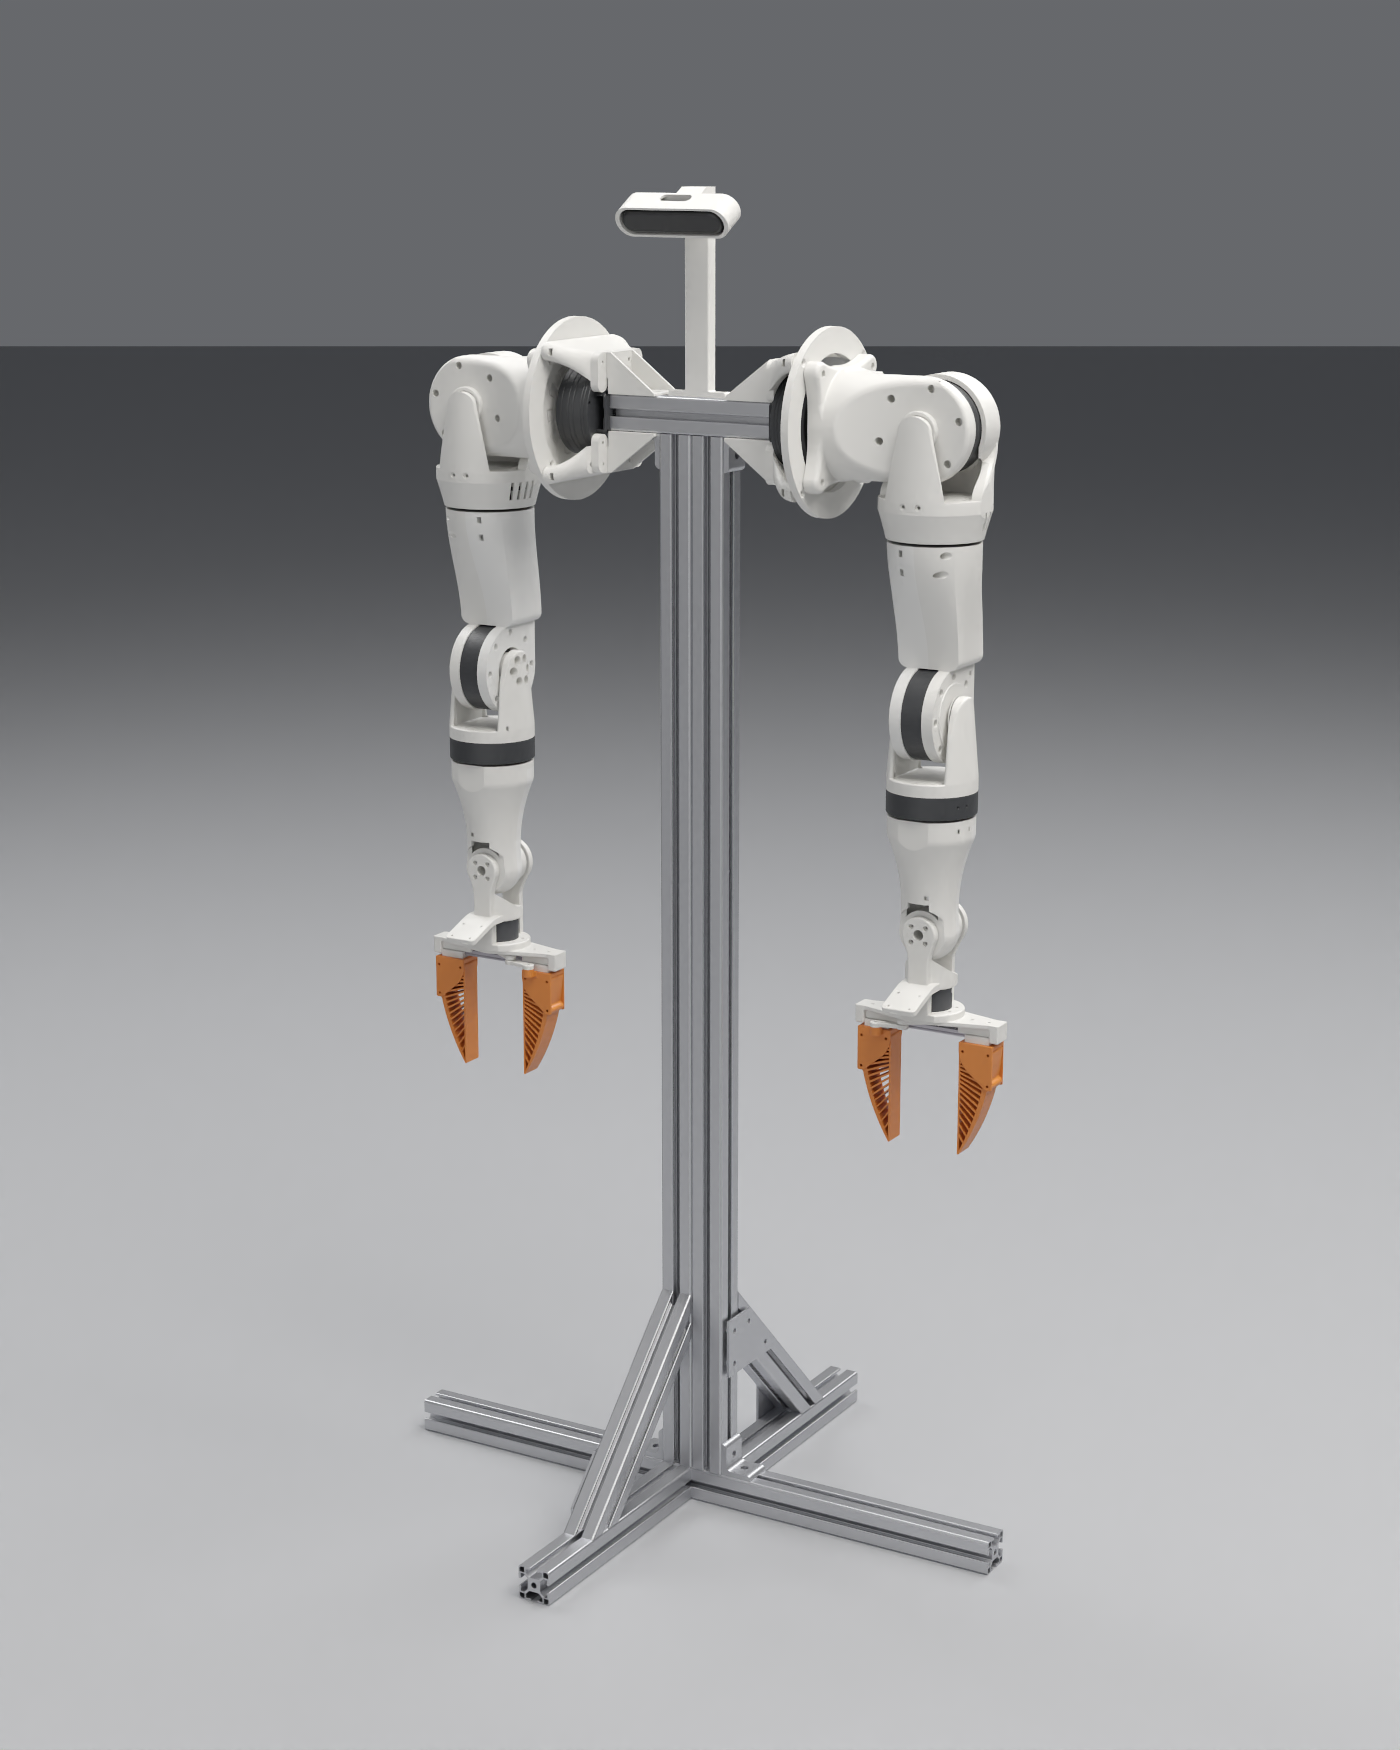
6 DOF Arm + 1 DOF Gripper — Motor Selection
For faster progress, we will be temporarily switching to attaching a gripper instead of the 15 DOF hands for the arm.
| Rated Torque | Peak Torque | ||
|---|---|---|---|
| Shoulder (1-2) | AK10-9 V3.0 | 18Nm | 53Nm |
| Elbow (3-4-5) | AK80-9 V3.0 | 9Nm | 22Nm |
| Wrist (6) | GL40 II KV82.5 | 0.25Nm | 0.73Nm |
| Gripper (7) | GL40 II KV82.5 | 0.25Nm | 0.73Nm |
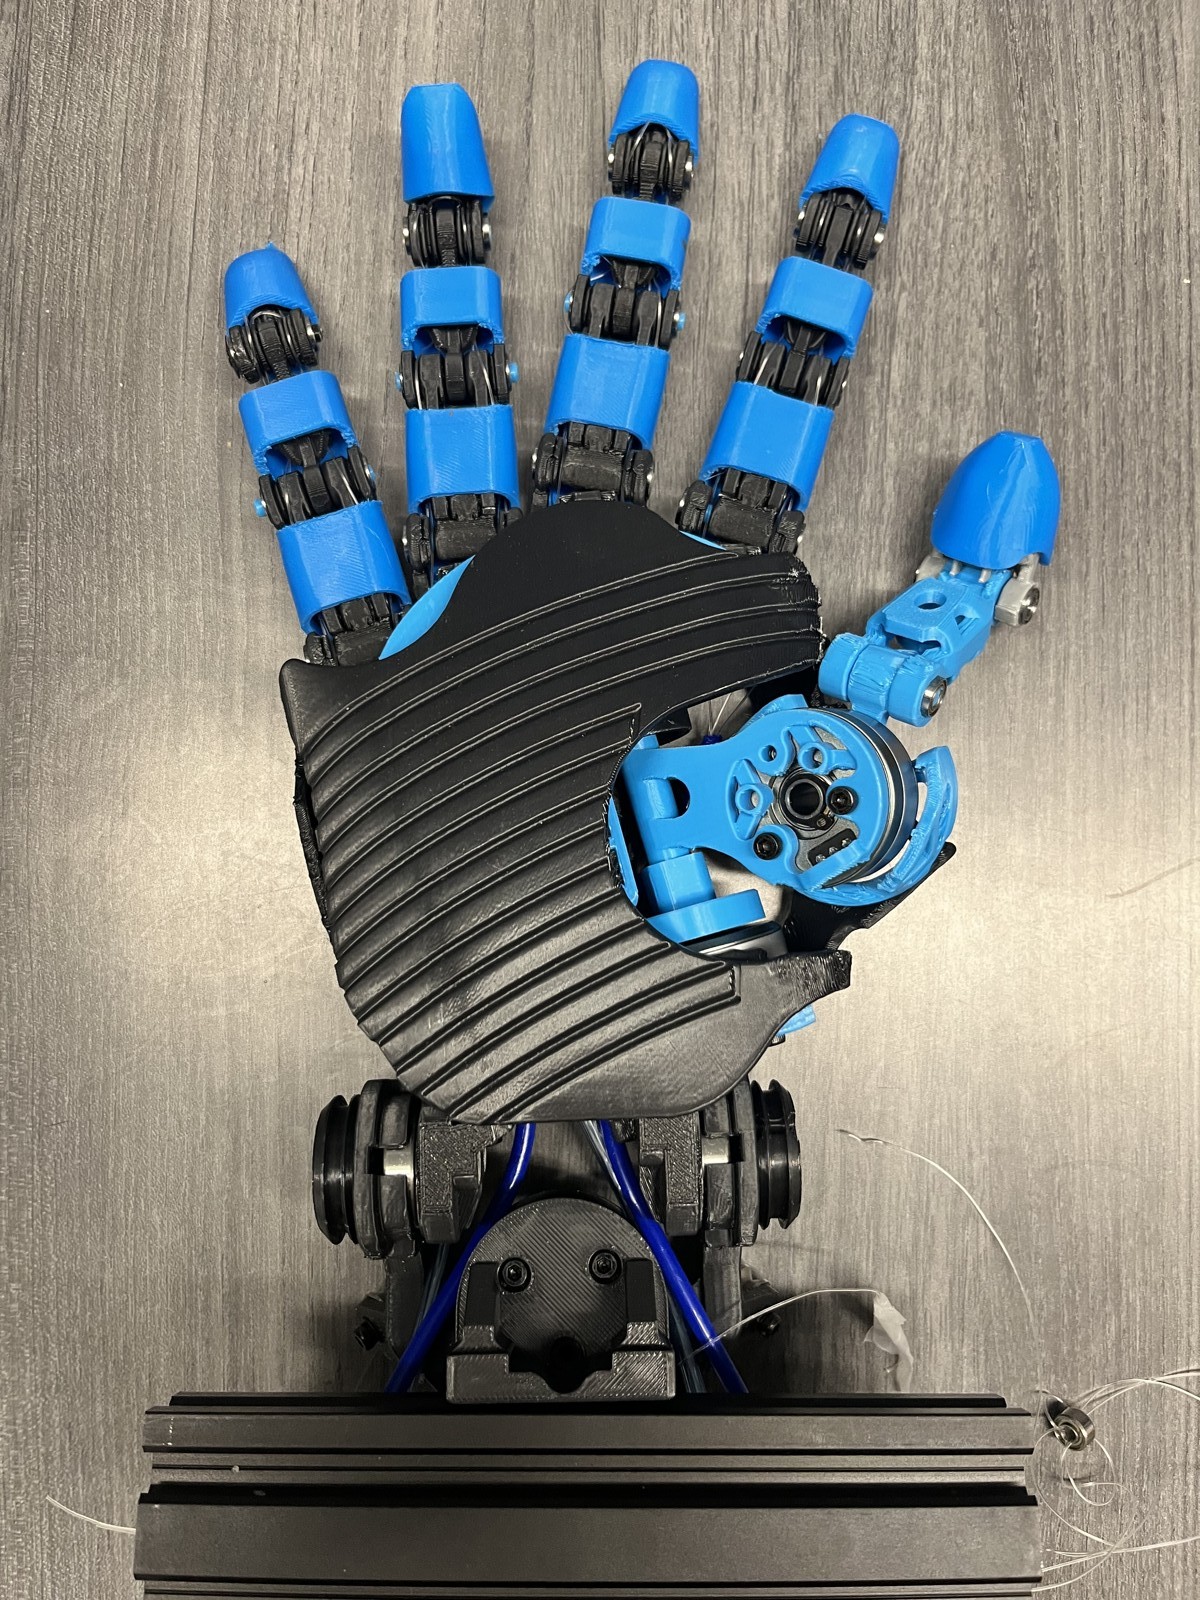
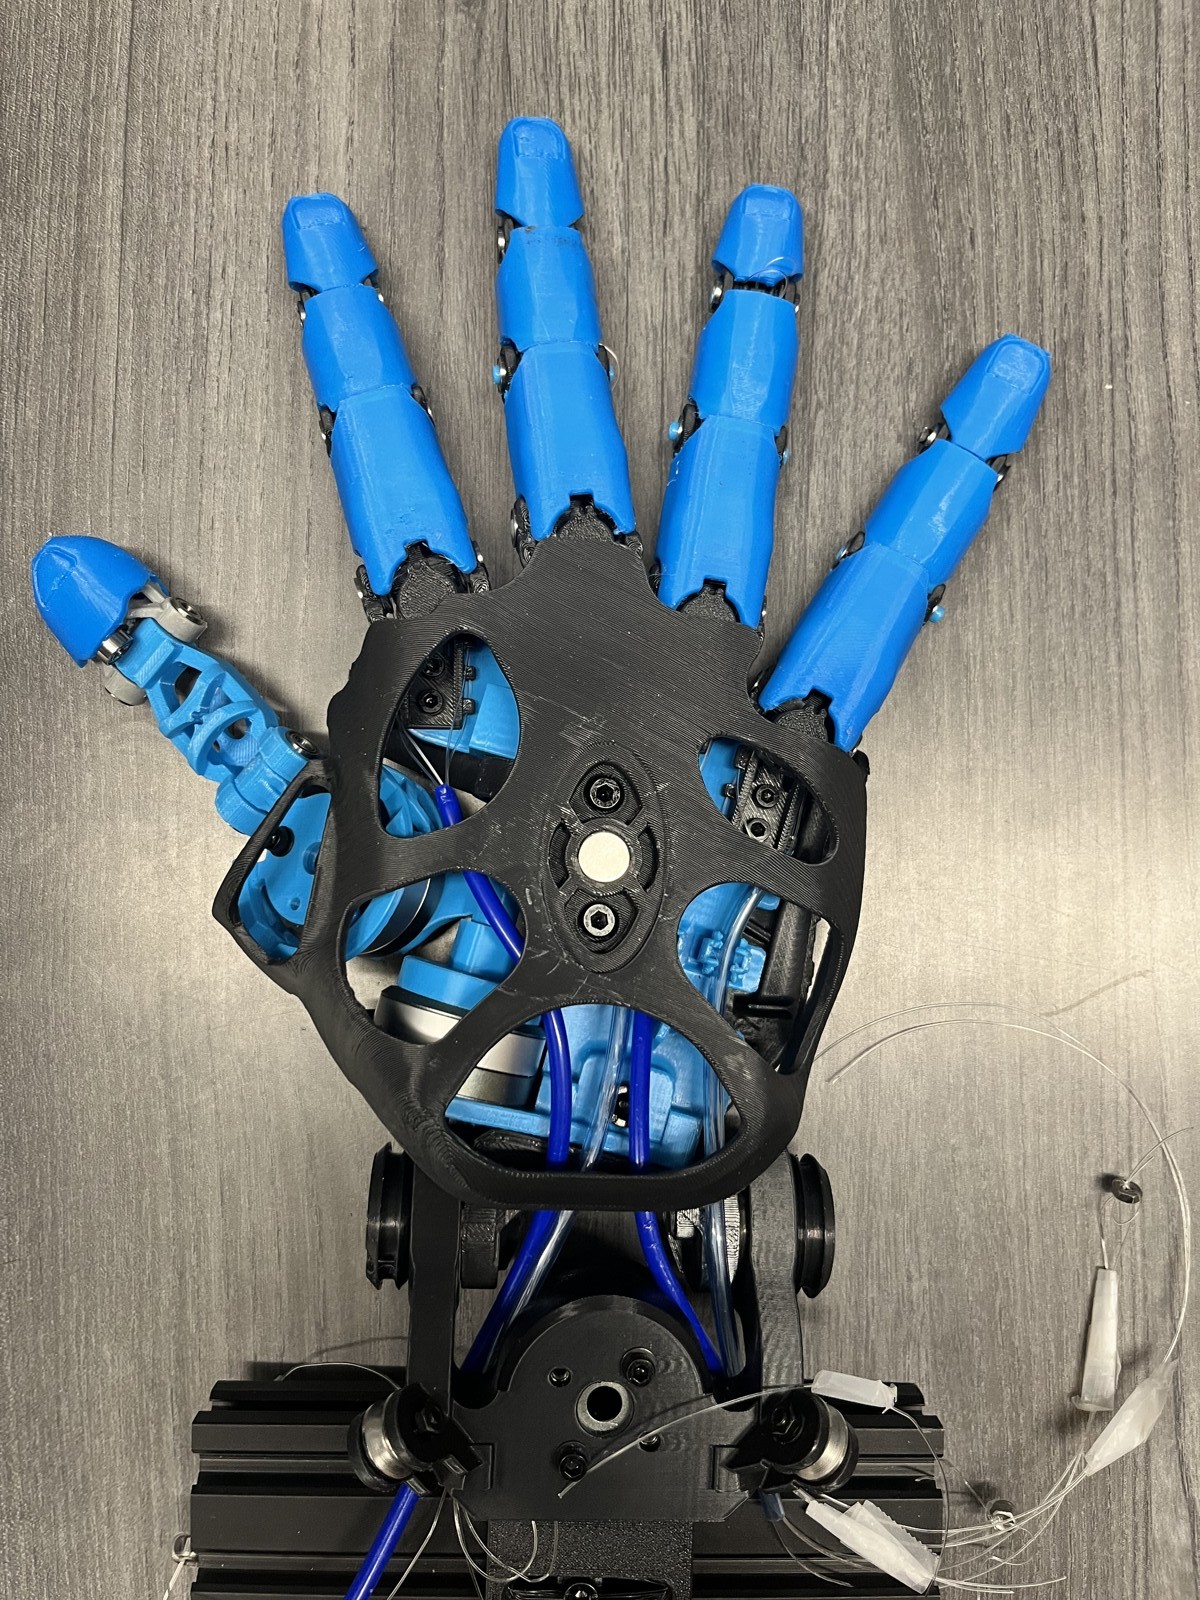
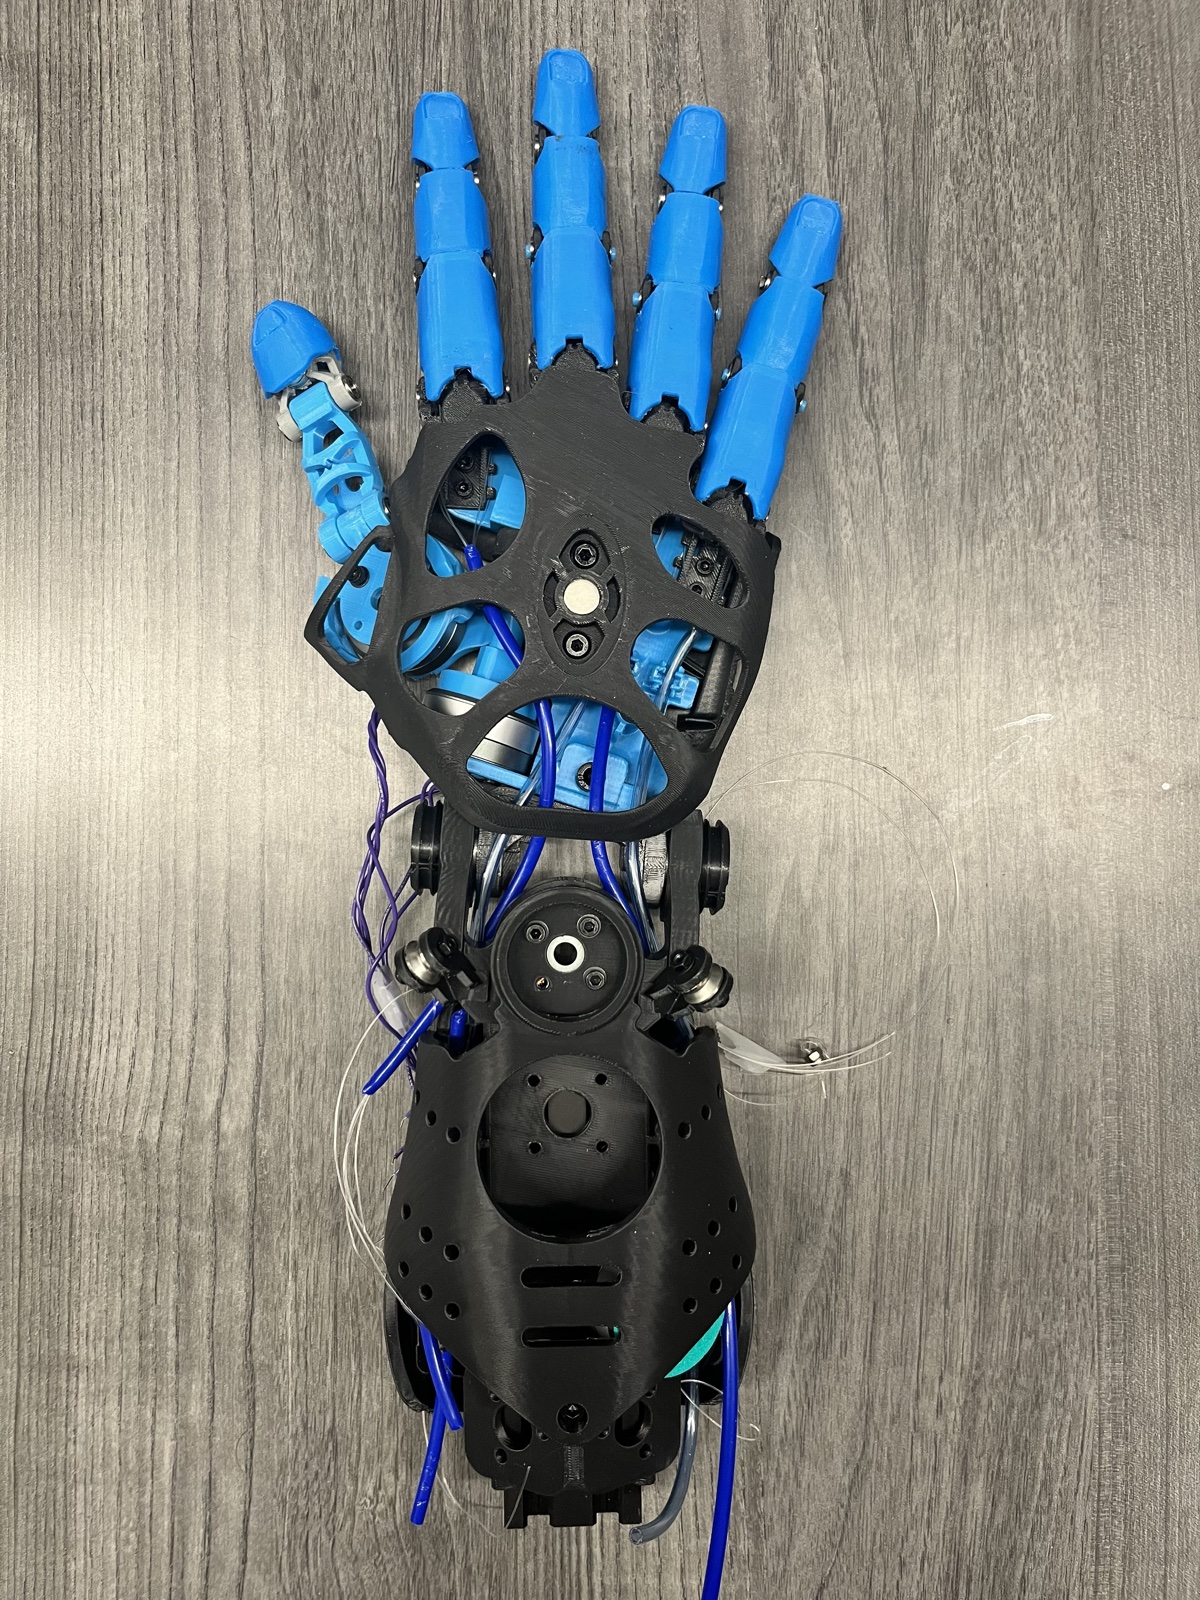
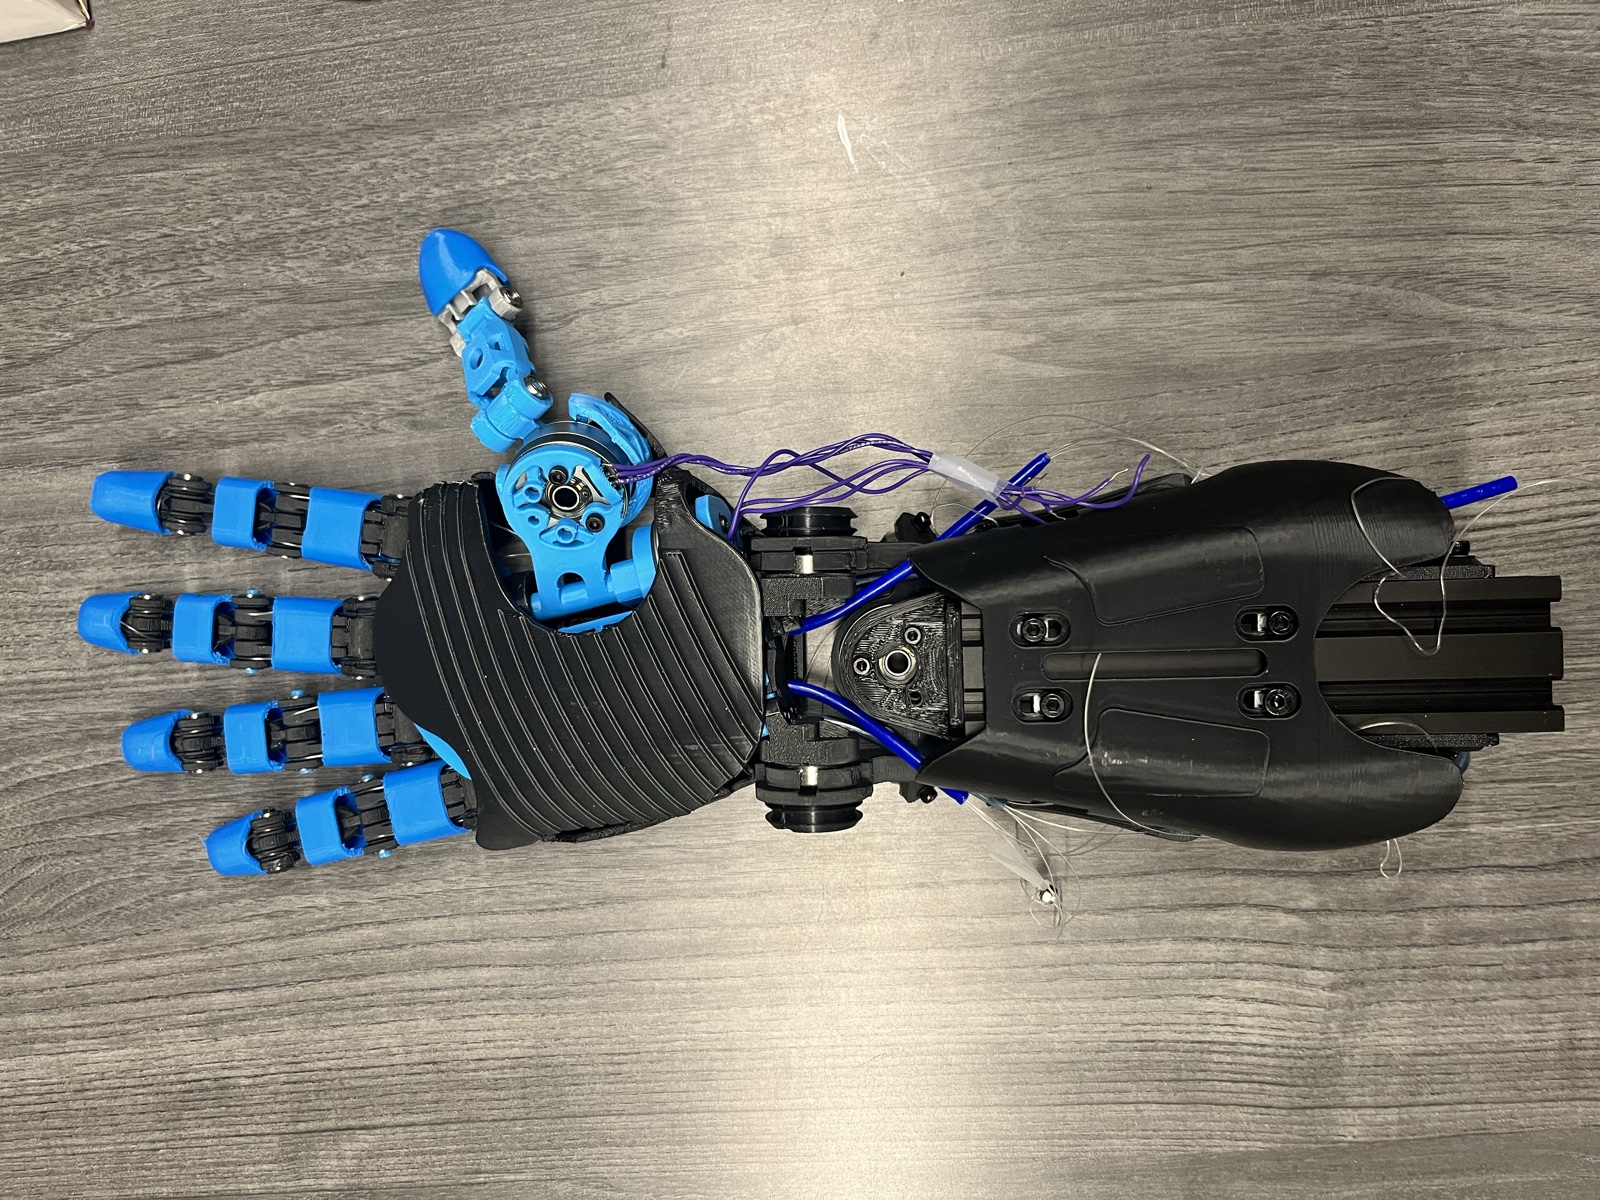
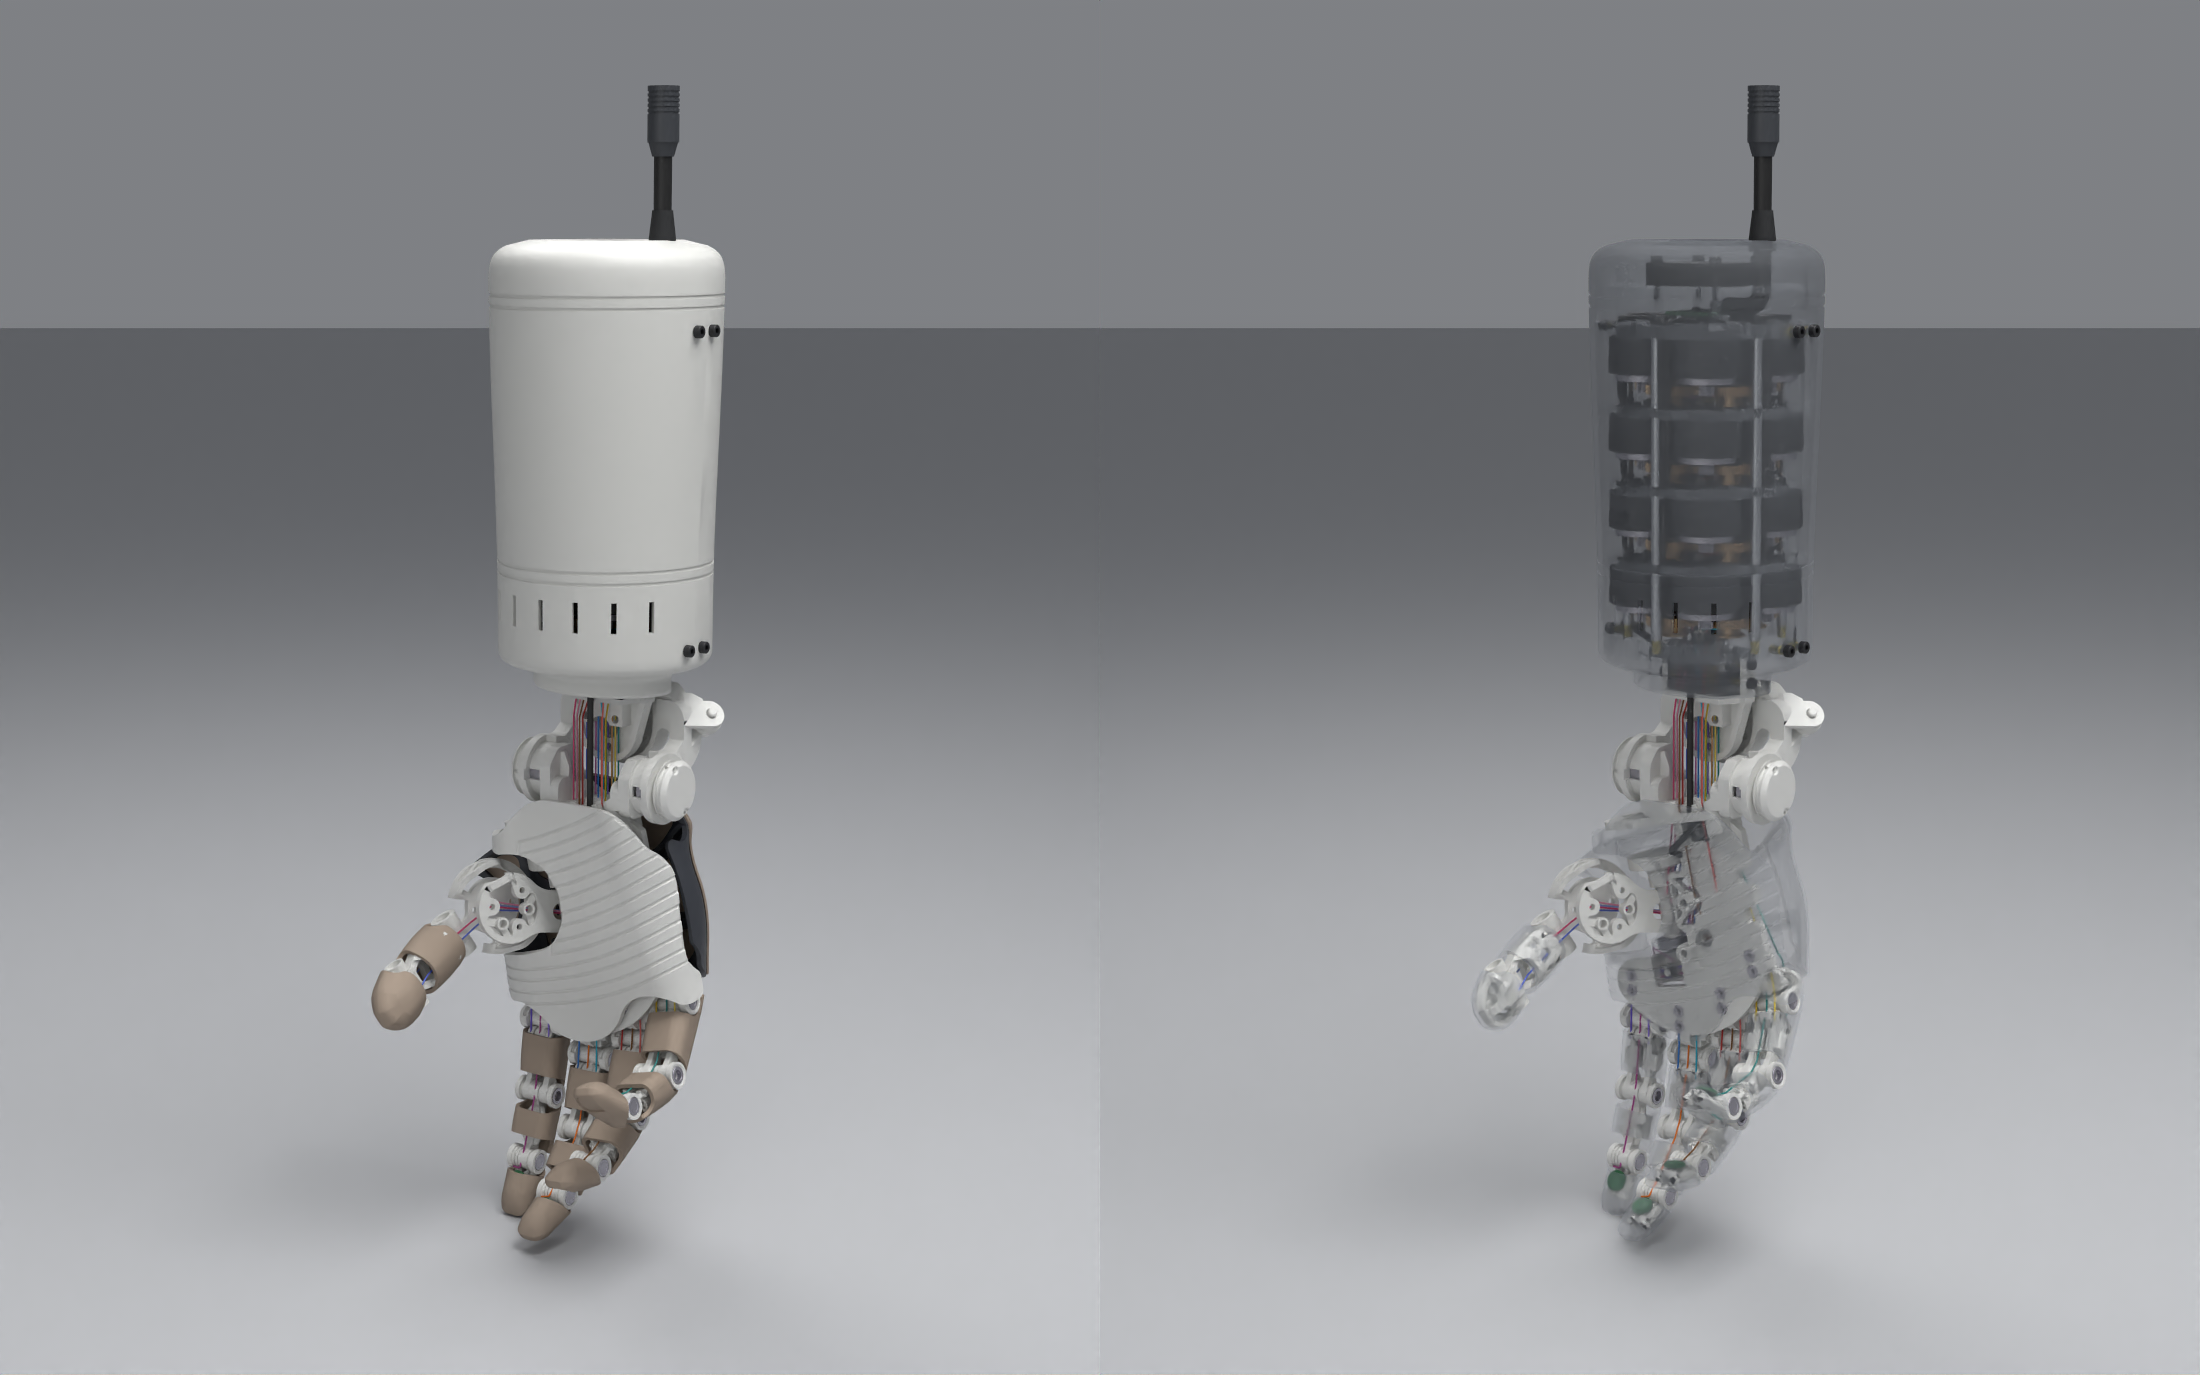
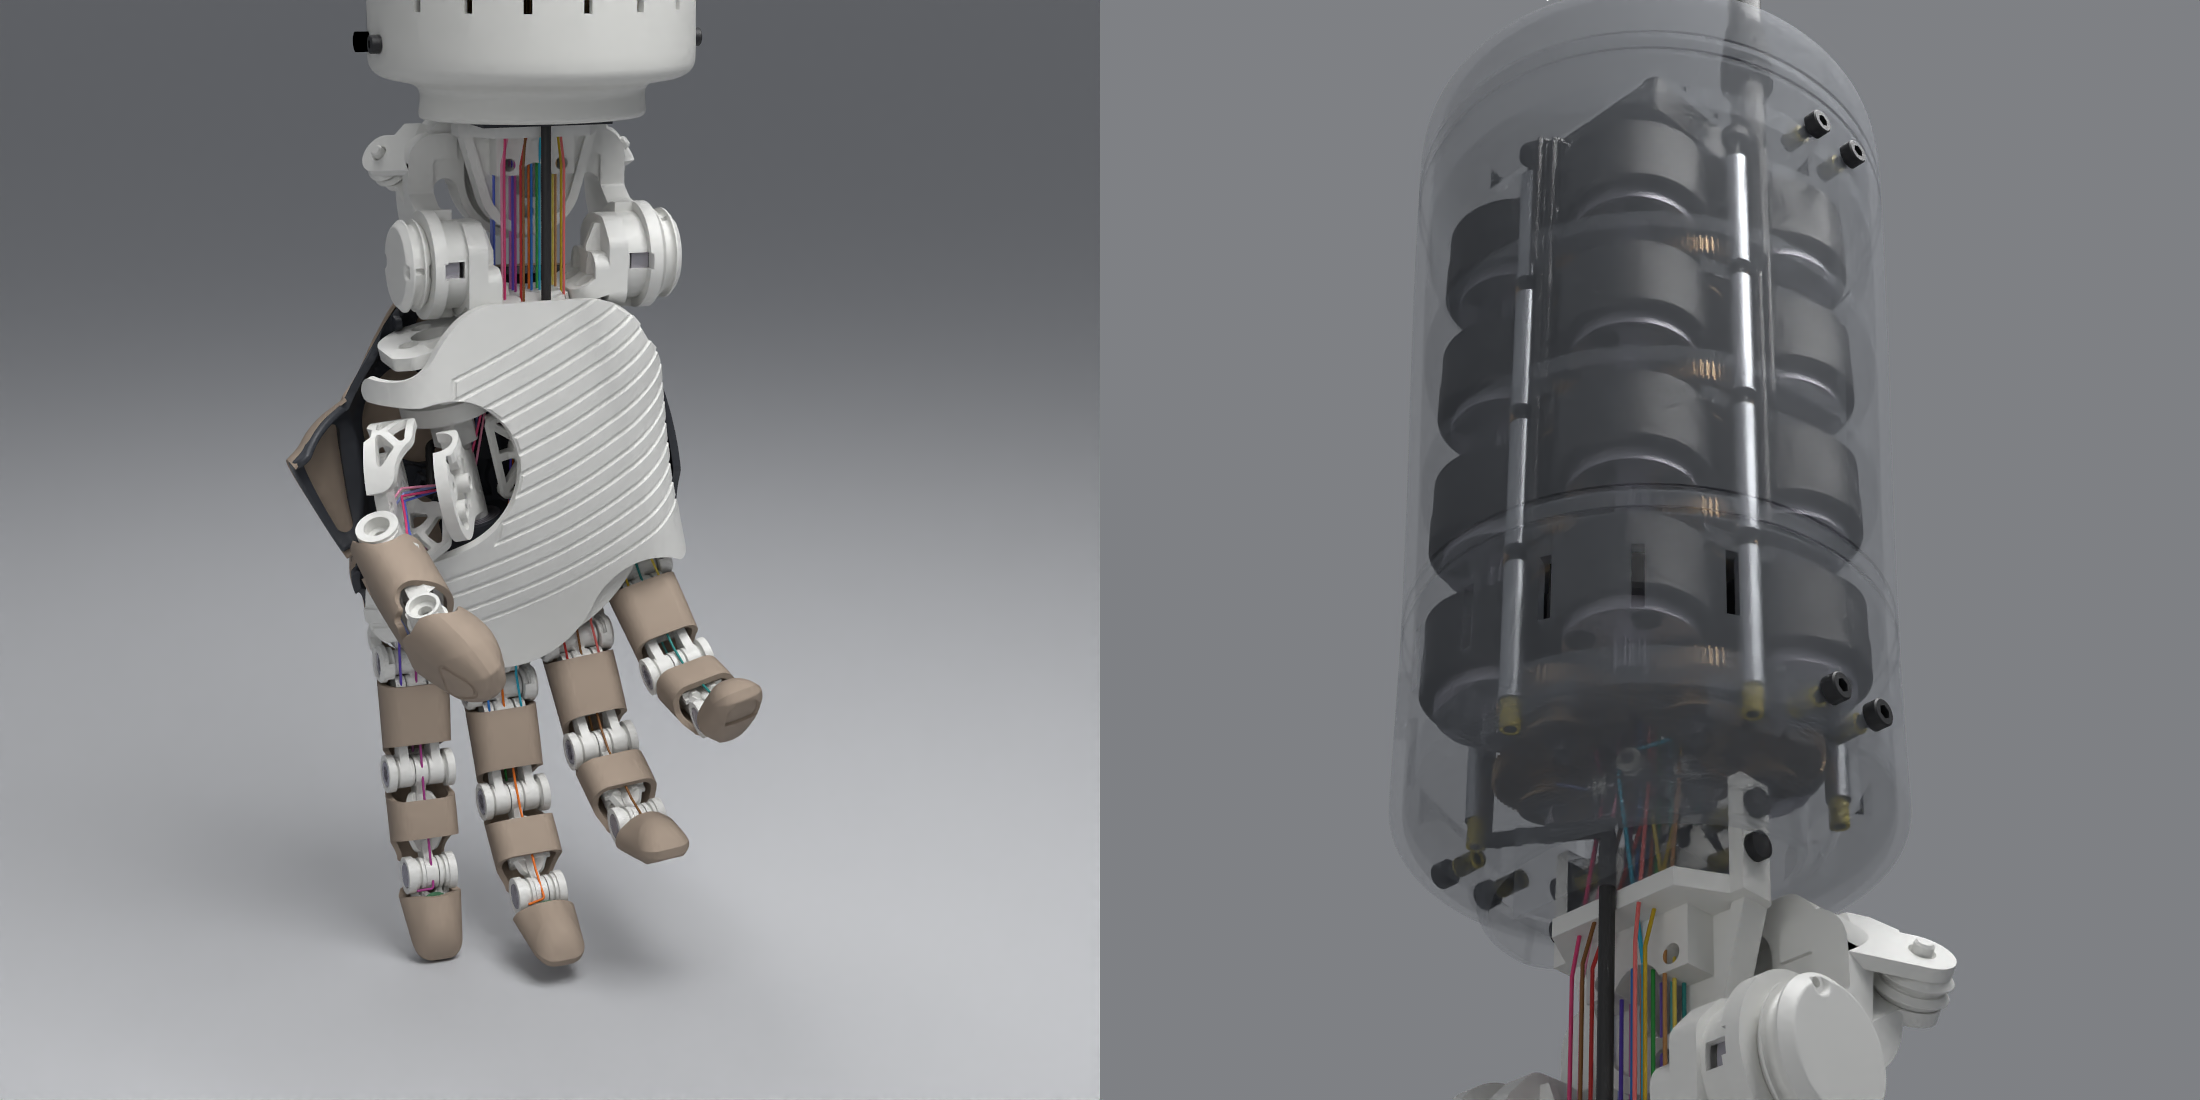
22 DOF Hand
22 DOF hand (18 actuated), including 2 DOF for the wrist.
Humanoid Leg
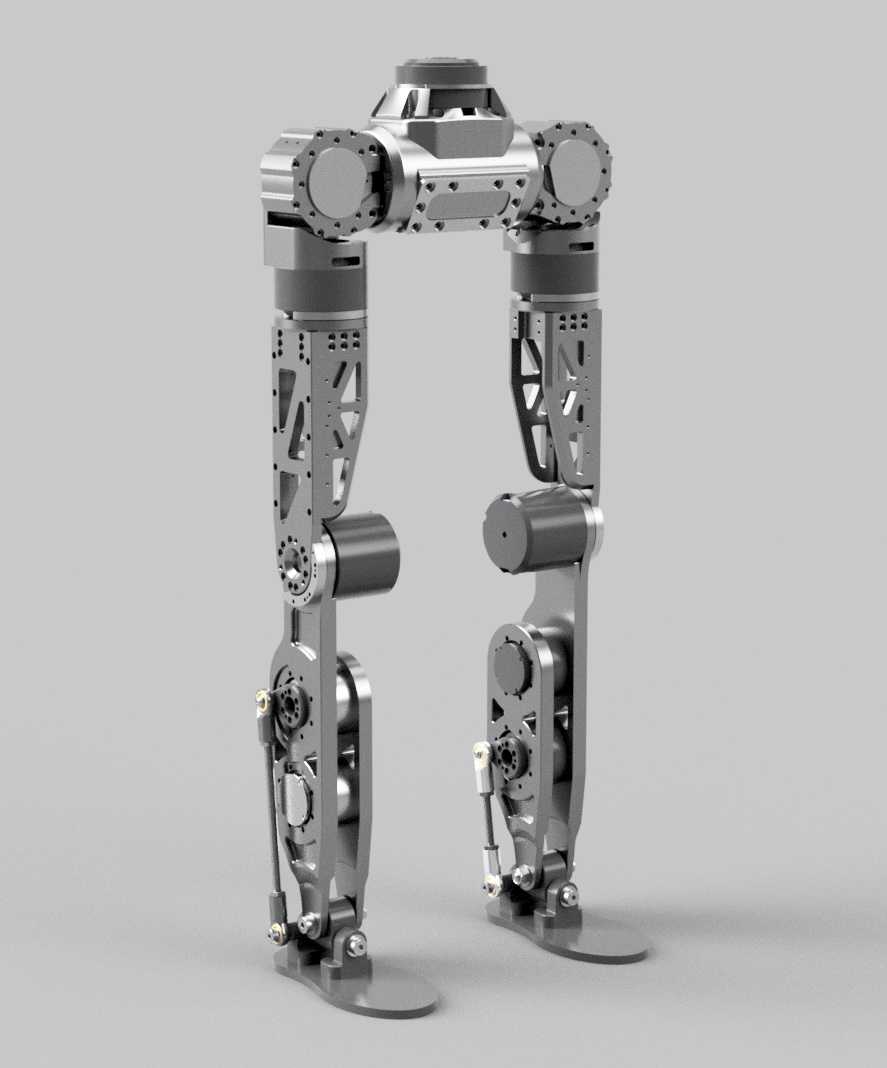
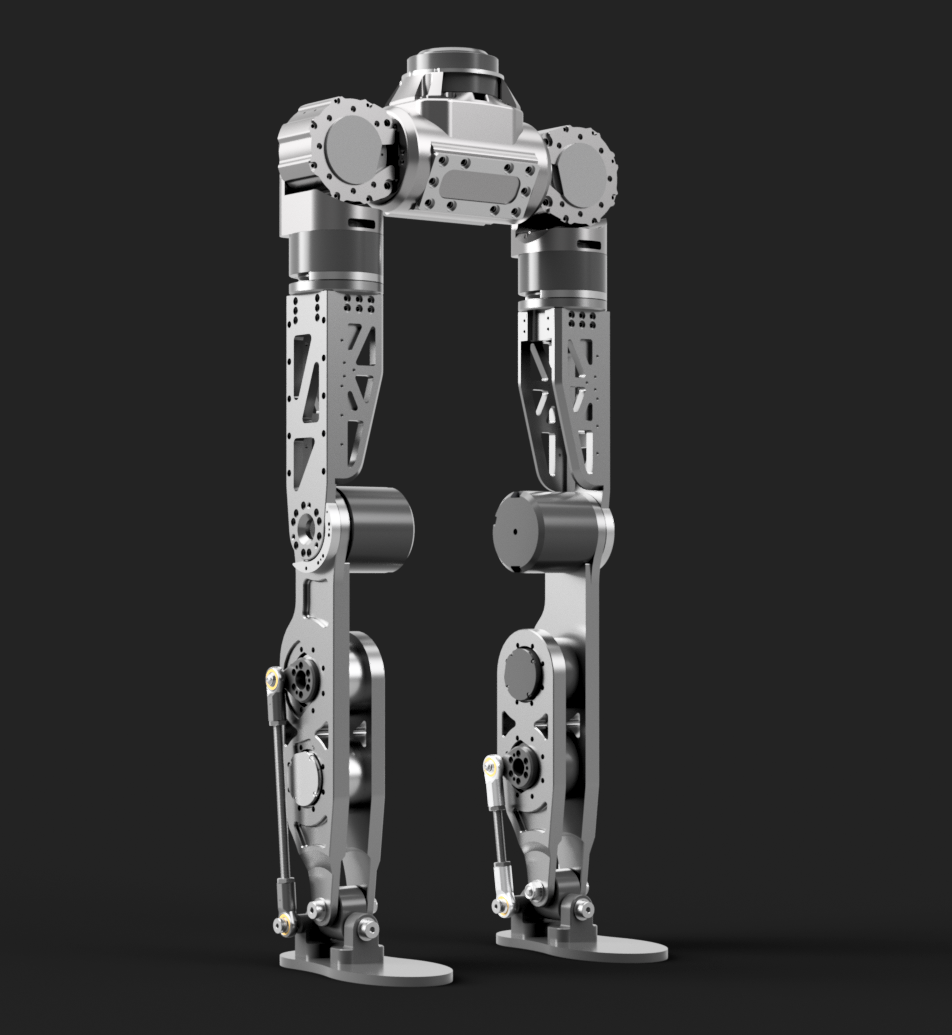
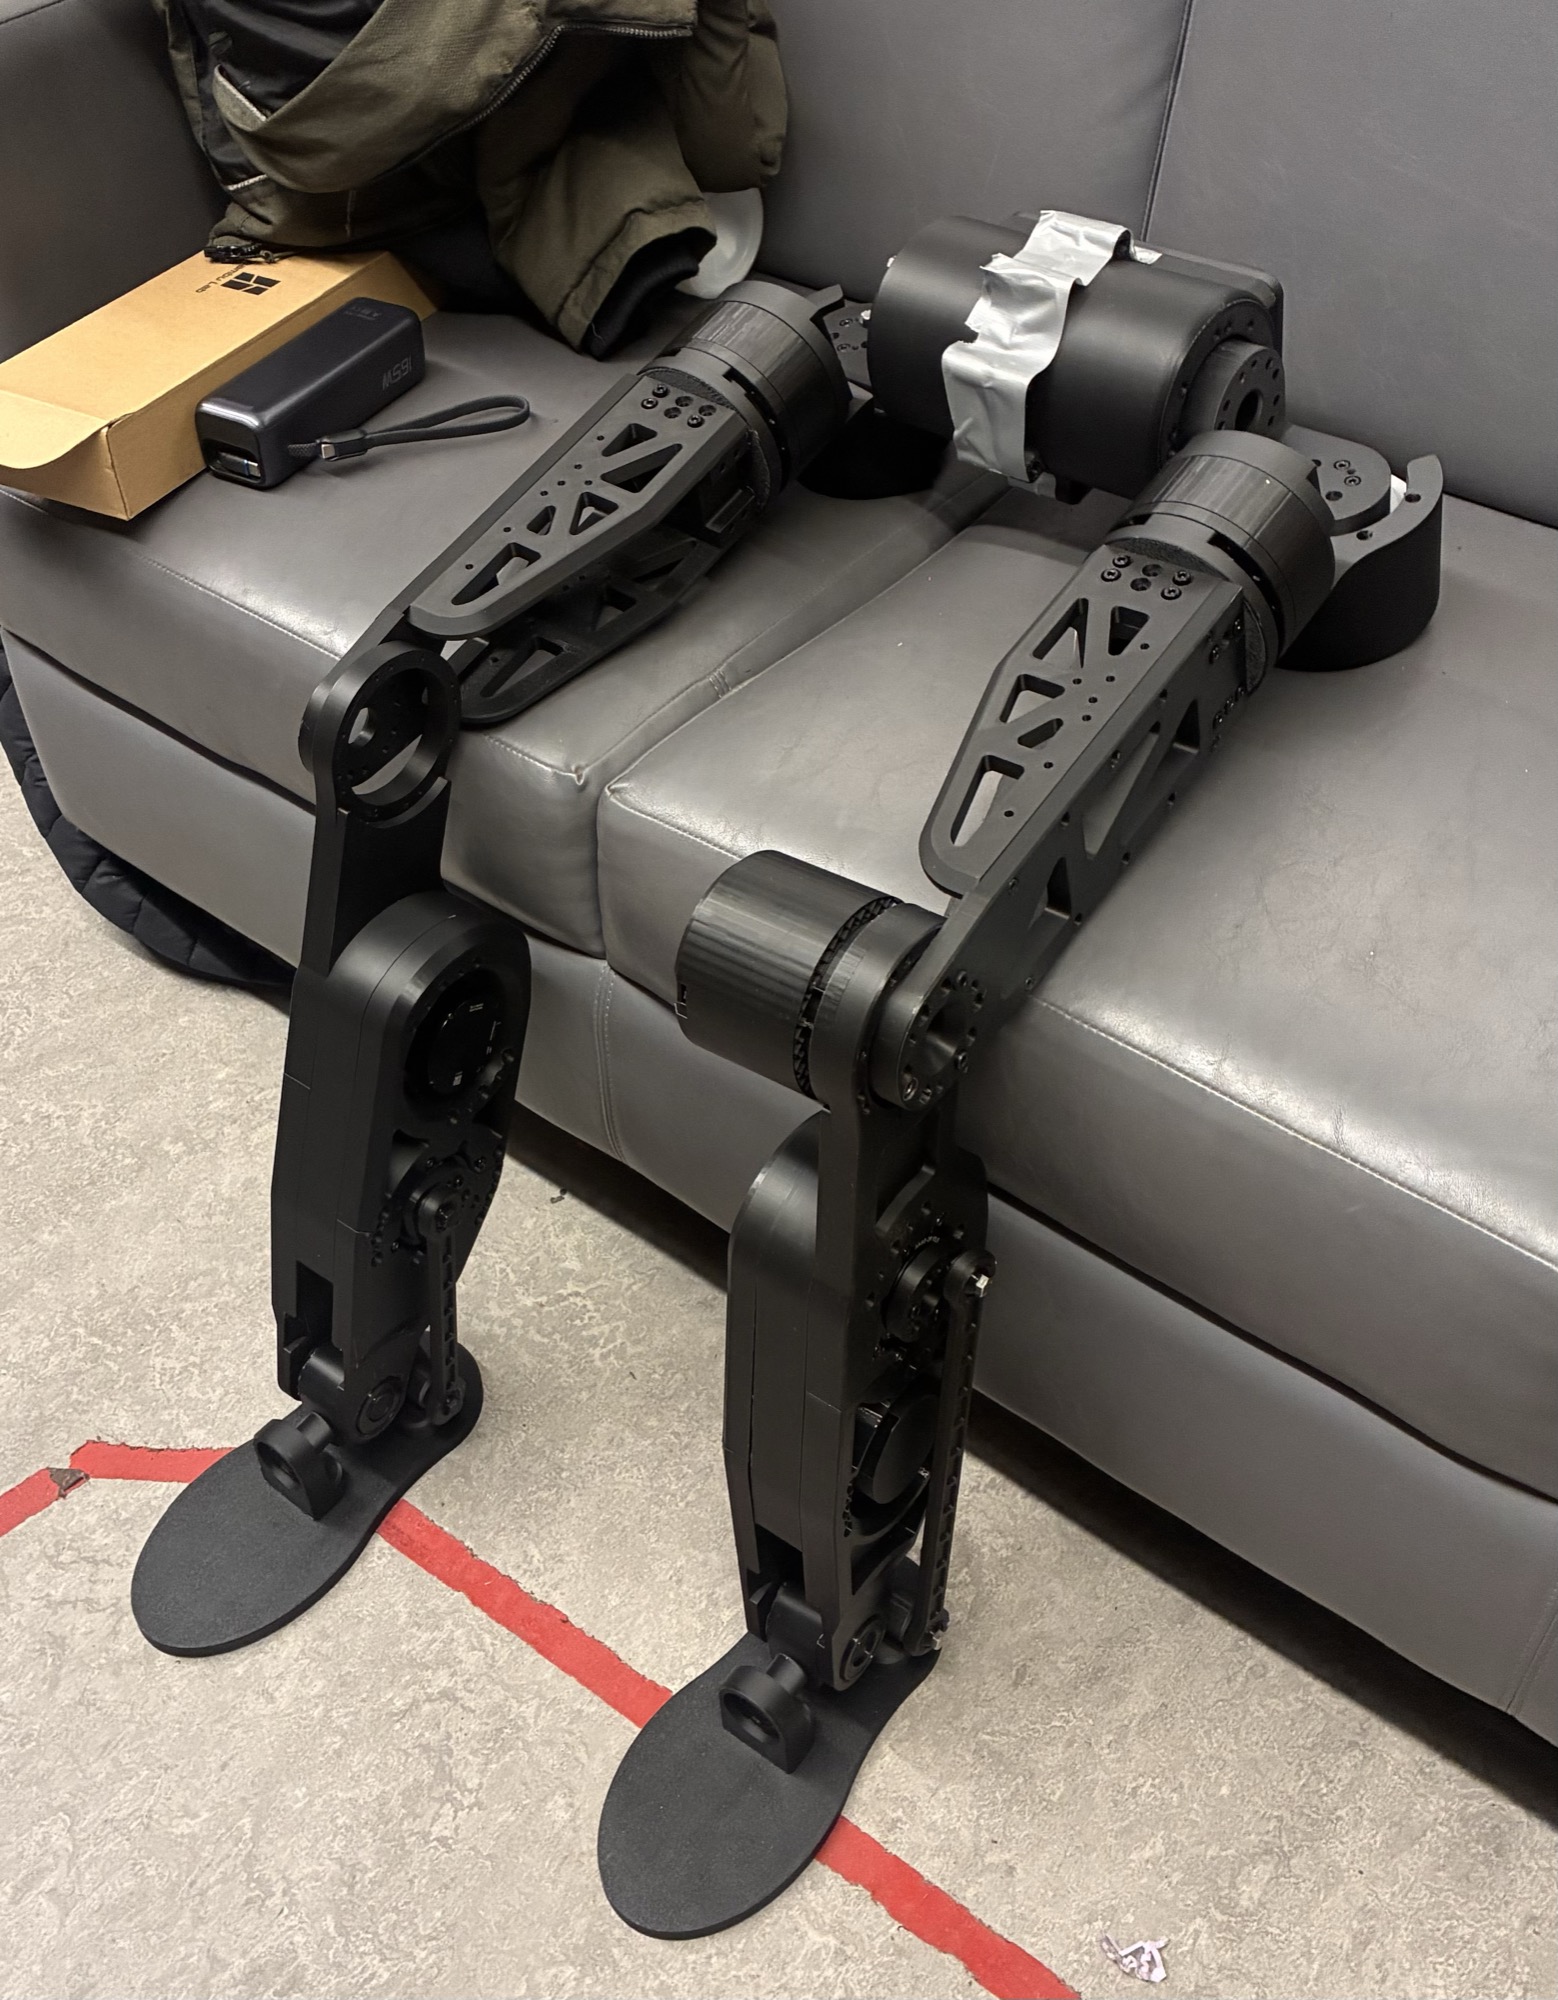
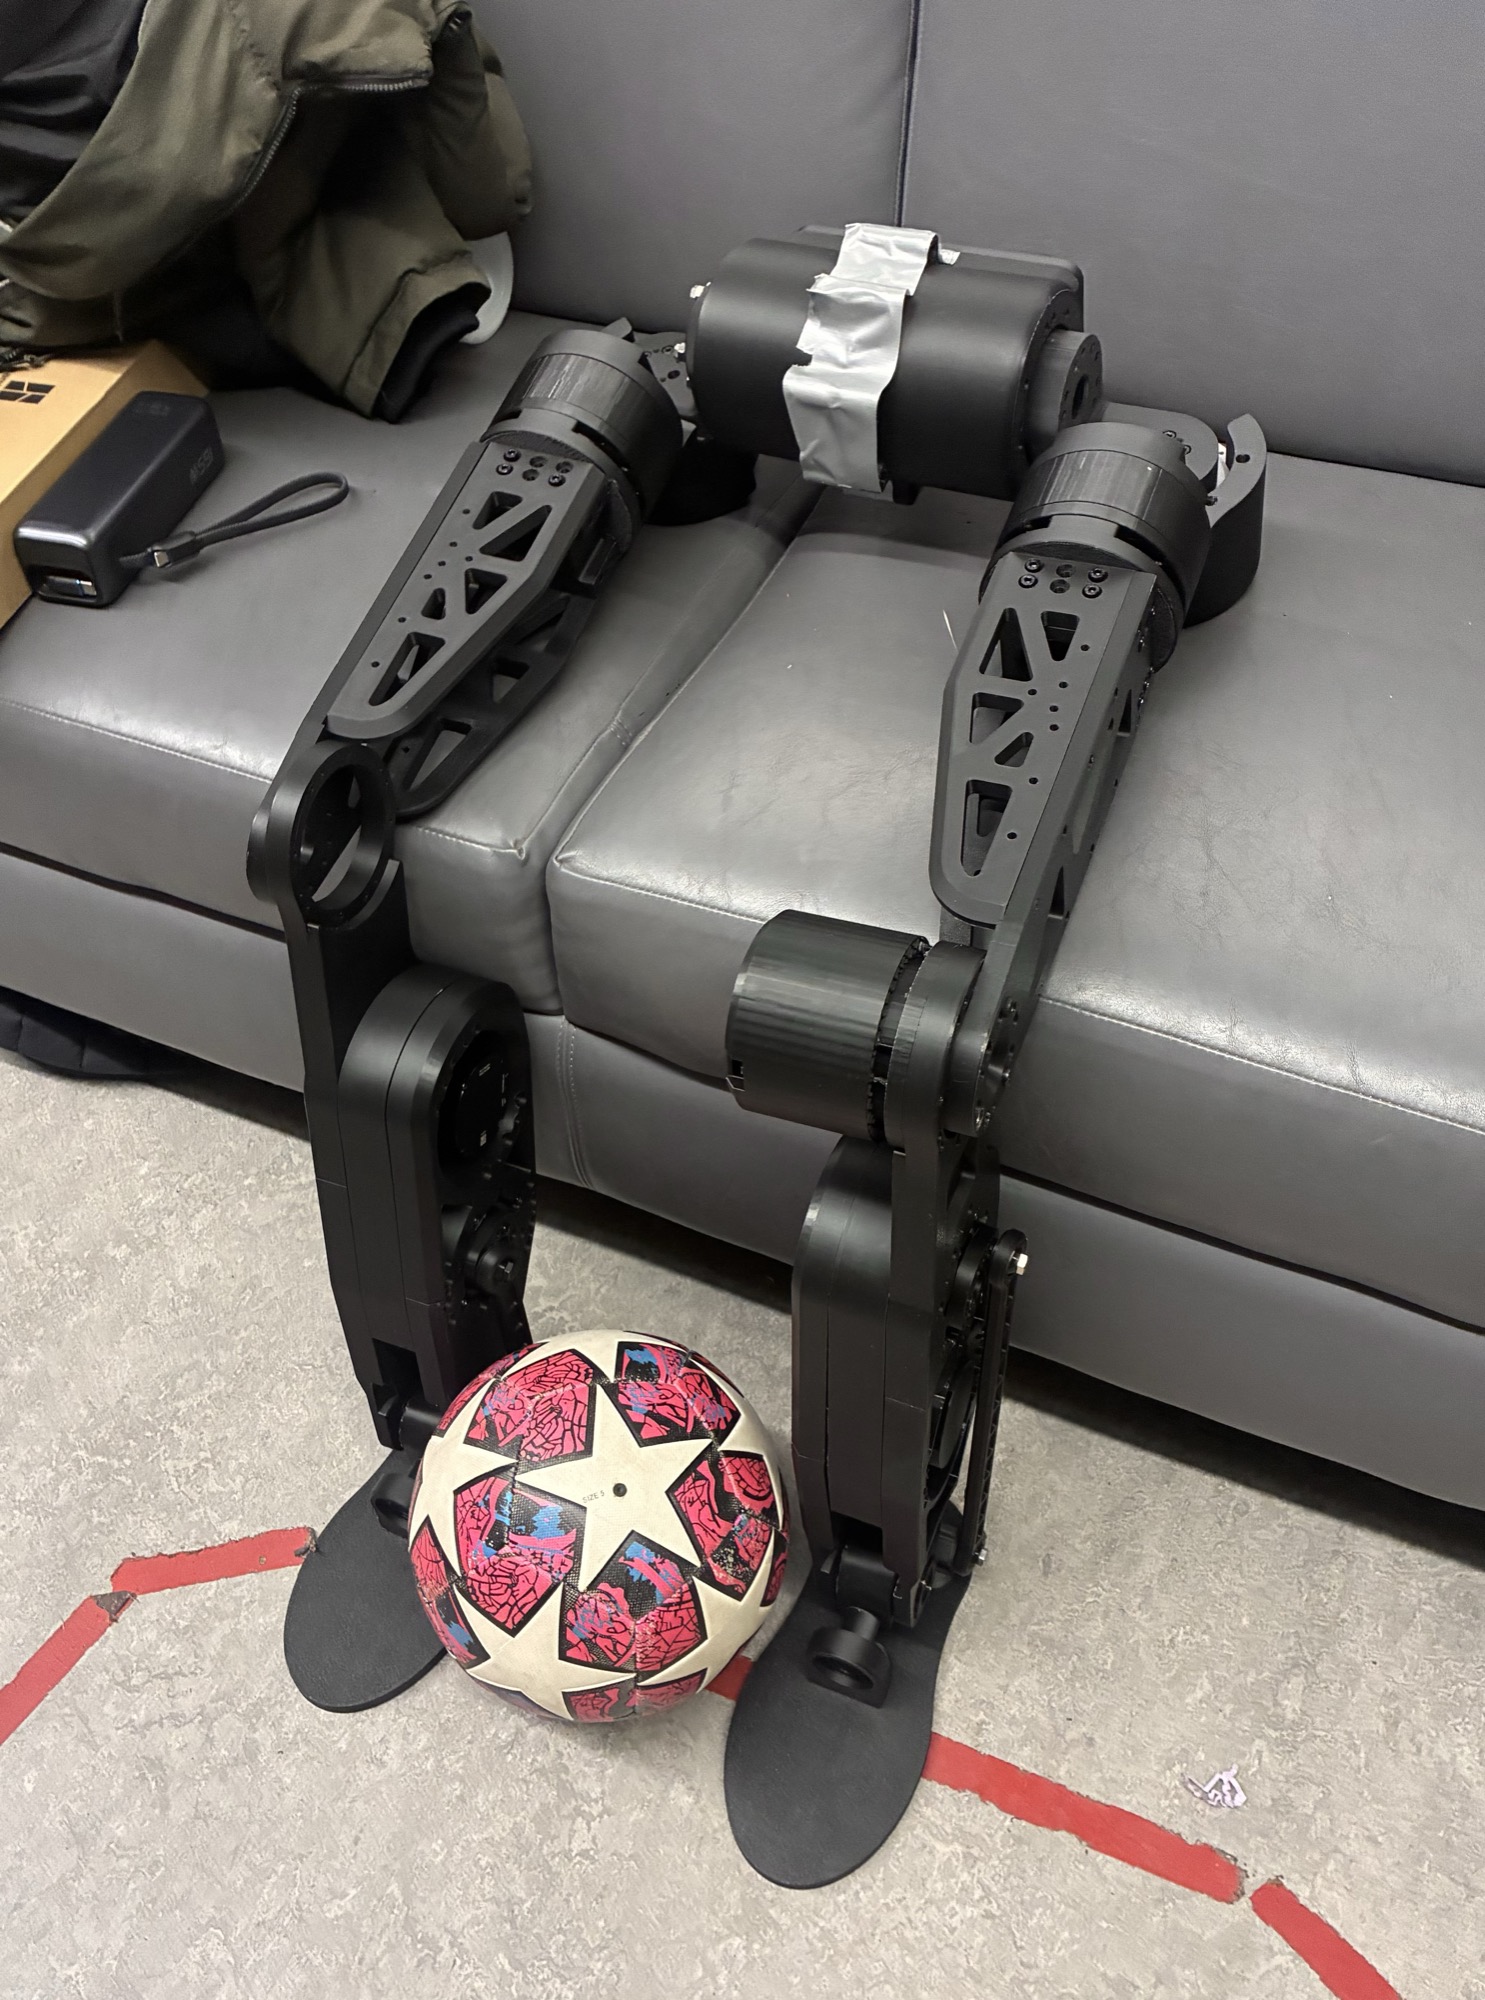
6 DOF Per Leg — Motor Selection
| Joint | DOF | Motor | Range (deg) |
|---|---|---|---|
| Hip | Pitch (Hip_F) | AKH70-48 | −20 to +90 |
| Hip | Yaw (Hip_R) | AK60-39 V3.0 KV80 | −30 to +90 |
| Hip | Roll (Hip_A) | AK80-64 KV80 | −10 to +60 |
| Knee | Pitch | AKH70-48 | −65 to 0 |
| Ankle | Pitch (Ankle_P) | AK60-39 V3.0 KV80 | −30 to +50 |
| Ankle | Roll (Ankle_R) | AK60-39 V3.0 KV80 | −15 to +15 |
The ranges are the same on both legs. The whole robot: Whole-Body Humanoid.
Hip
The hip design uses the F-A-R (Flexion-Abduction-Rotation) configuration for a compact and biomimetic joint arrangement. This configuration allows for efficient packaging of the actuators while maintaining the necessary degrees of freedom for humanoid locomotion.