Whole-Body Humanoid
The finalized Pioneer whole-body design: a white helmet with a graphite visor frame on a white torso, the 5 DOF arms, the 22 DOF tendon hands and the 6 DOF legs. Left and right are mirror images, part for part.
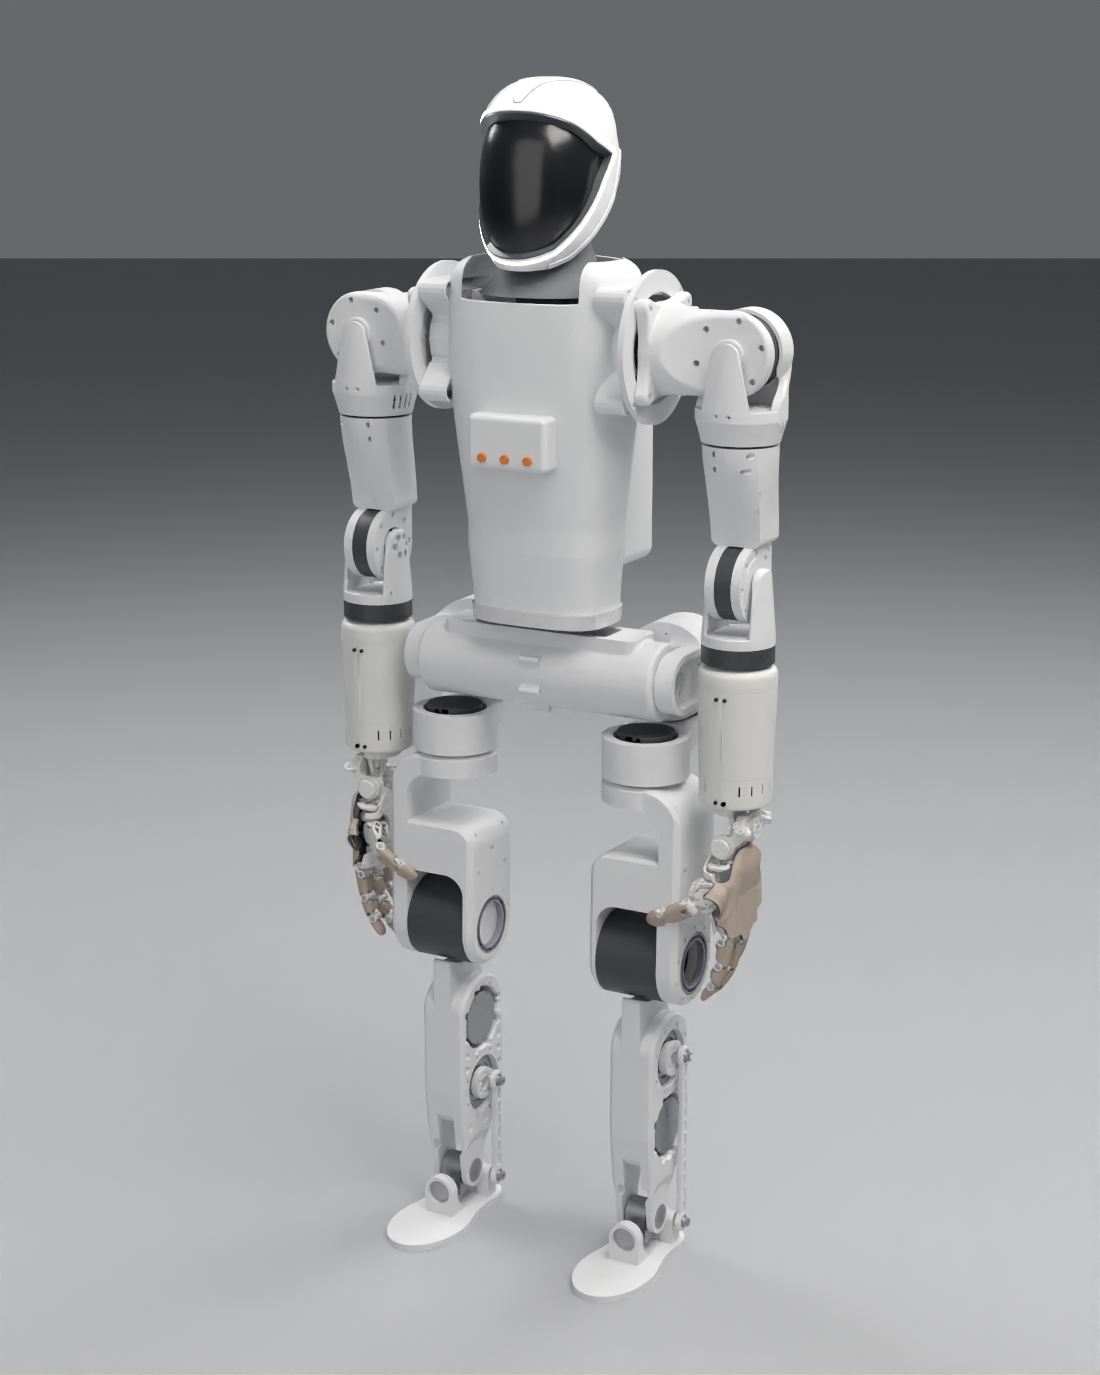
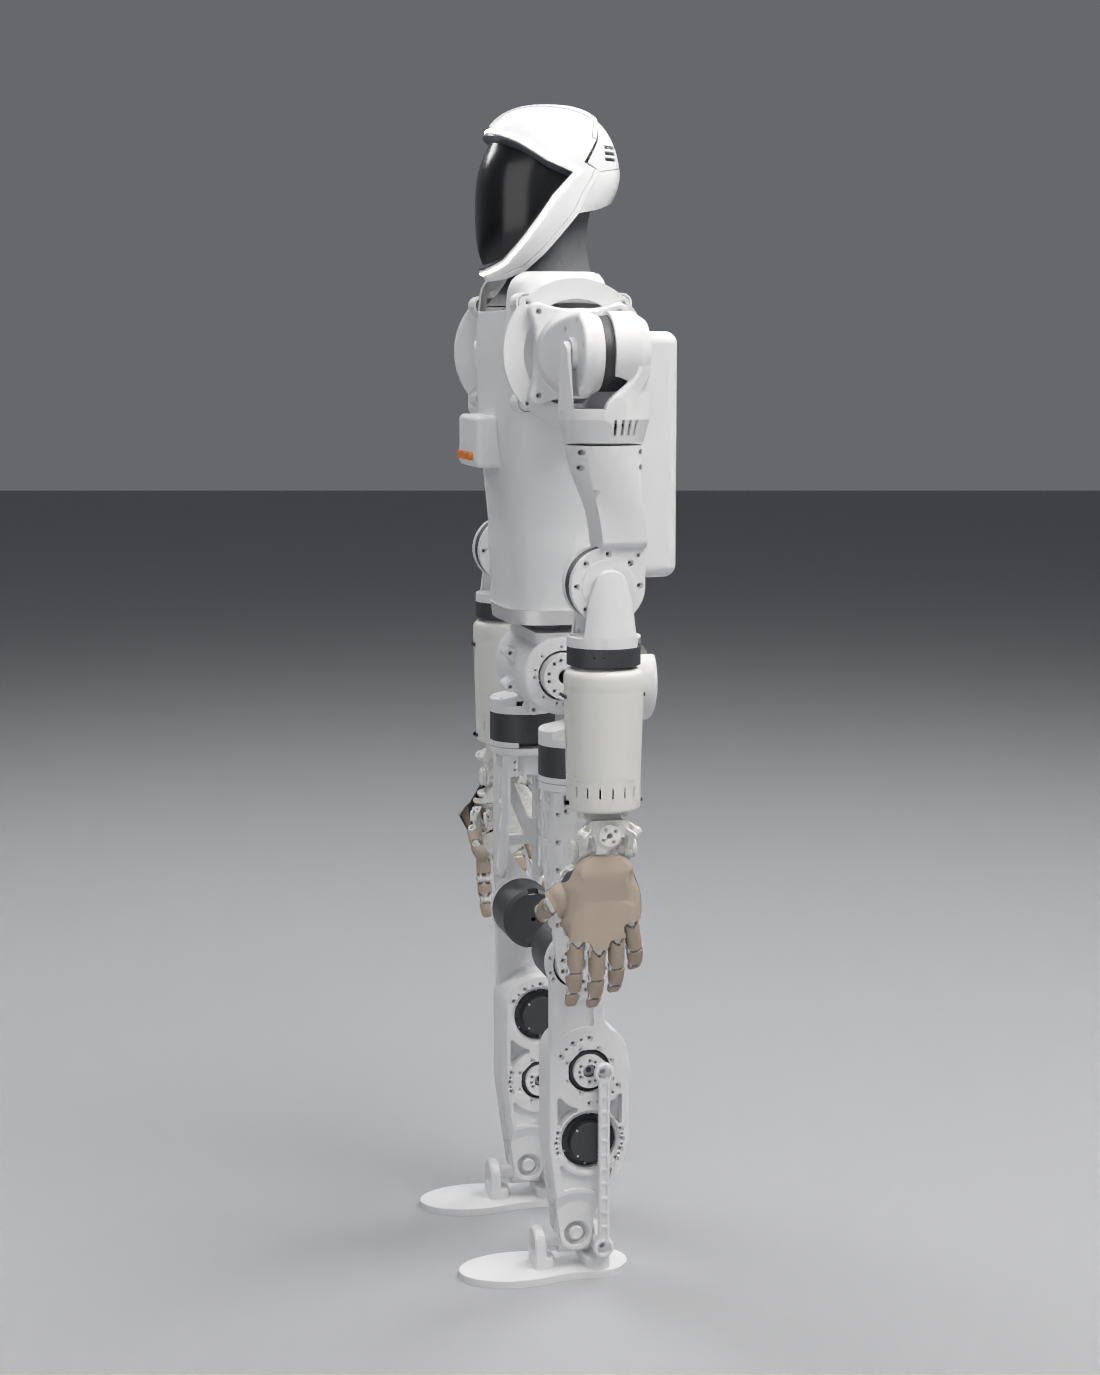
Head
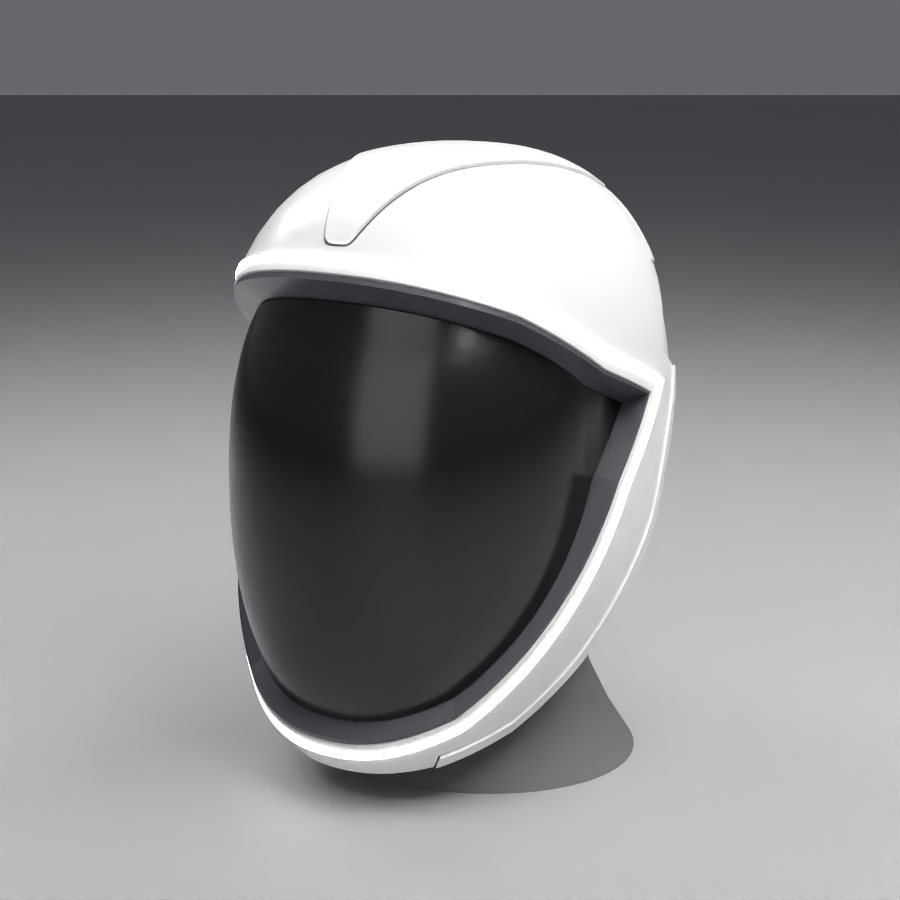
The helmet has a raked wedge visor in gloss black, recessed in a dark graphite frame with a light bar round it, a fanned rib over the crown, cheek pads and temple vents. The neck dam flares into the torso's collar.
67 Joints
| Group | Joints | Count |
|---|---|---|
| Waist | yaw | 1 |
| Arms | shoulder pitch, shoulder roll, upper arm yaw, elbow, forearm roll | 5 × 2 = 10 |
| Hands | wrist flexion and deviation (2); index, middle, ring and little fingers: spread, MCP, PIP, DIP (4 × 4 = 16); thumb: CMC × 2, MCP, IP (4) | 22 × 2 = 44 |
| Legs | Hip_F, Hip_A, Hip_R, Knee, Ankle_P, Ankle_R | 6 × 2 = 12 |
| Total | 67 |
Each finger's DIP is coupled to its PIP by a cross-cable, so each hand has 18 actuated joints of its 22 (see Tendon Hand).
Leg Joint Limits
The same on both legs. The left and right axes mirror each other, so a positive angle moves either leg the same way: a positive Hip_A spreads the leg outward, a positive Ankle_P points the toes down.
| Joint | DOF | Range (deg) |
|---|---|---|
| Hip_F | Hip pitch | −20 to +90 |
| Hip_A | Hip roll | −10 to +60 |
| Hip_R | Hip yaw | −30 to +90 |
| Knee | Knee pitch | −65 to 0 |
| Ankle_P | Ankle pitch | −30 to +50 |
| Ankle_R | Ankle roll | −15 to +15 |
Arm Joint Limits
The range of motion the arm is designed for, the same on both arms. It covers the five arm joints and the two-axis wrist.
| Joint | Range (deg) |
|---|---|
| Shoulder pitch | −90 to +180 |
| Shoulder roll | −20 to +160 |
| Upper arm yaw | −120 to +120 |
| Elbow | 0 to 130 (bend) |
| Forearm roll | −110 to +110 |
| Wrist pitch | −60 to +60 |
| Wrist yaw | −90 to +90 |